Square One Systems Design supports the world’s most powerful X-ray laser at SLAC National Accelerator Laboratory using PC-based control, EtherCAT communications and robotics to speed research.
Robotic motion system insights
- Tri-Sphere Robotic Positioning System speeds up research at SLAC National Accelerator Laboratory by reducing equipment changeovers from two days to just 12 hours
- Robotic motion control provide precise positioning.
- Integrated automation, motion control and communications technologies help.
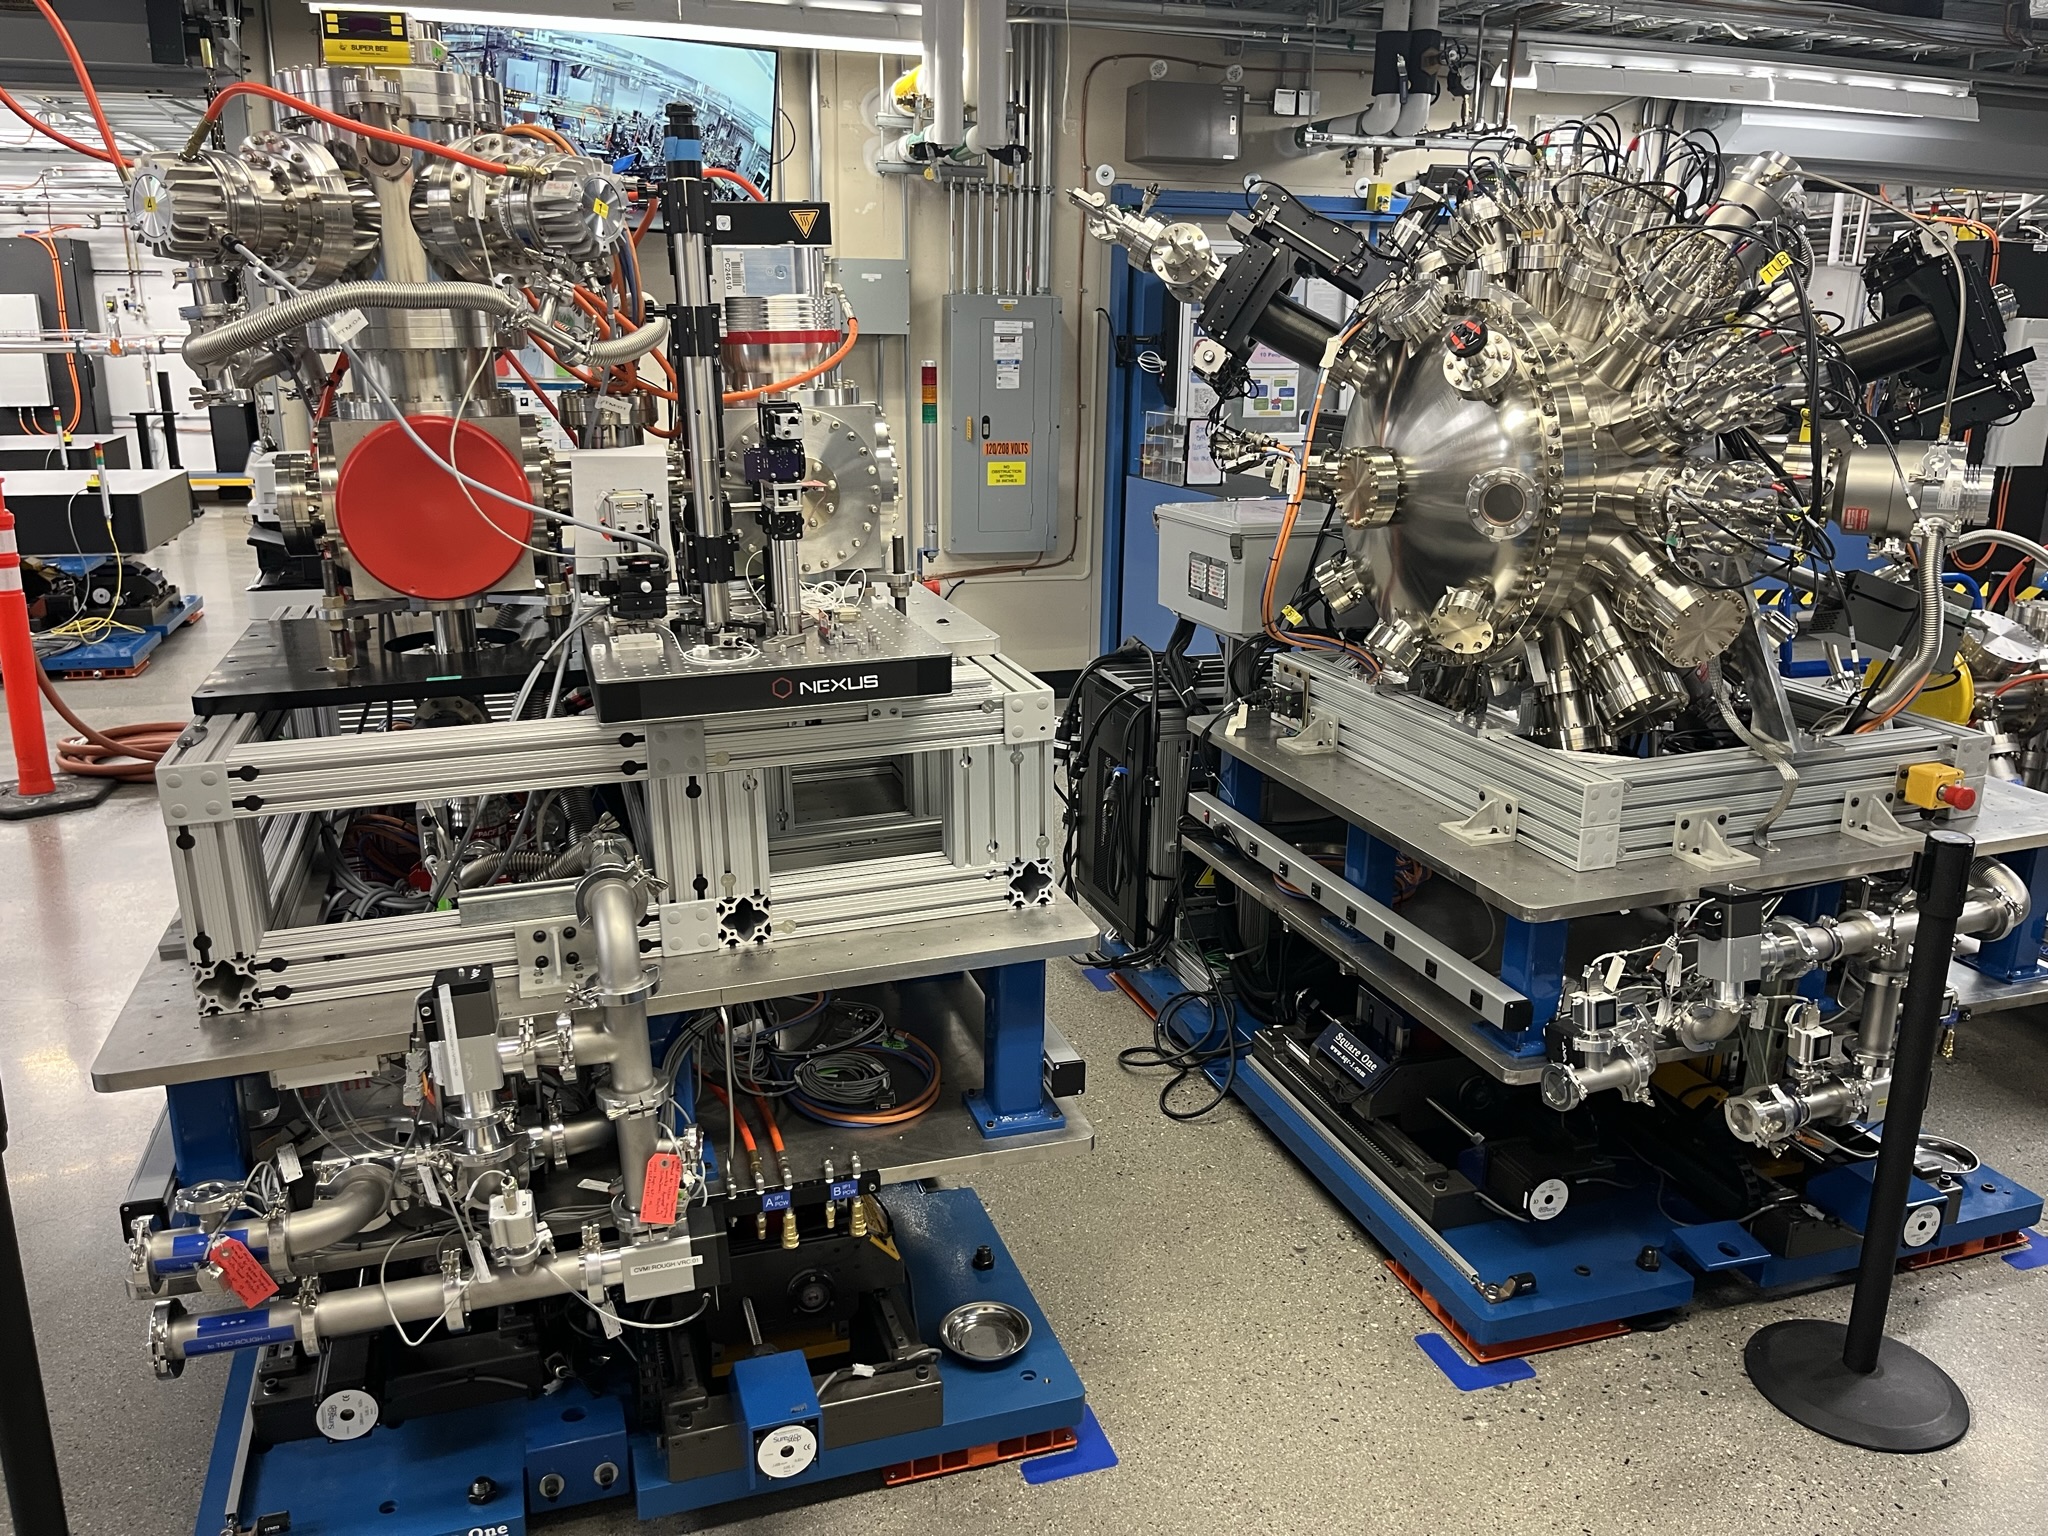
At SLAC National Accelerator Laboratory in Menlo Park, California, an advanced robotic system by Square One Systems Design and Beckhoff USA helps with maximizing access for researchers, streamlining operations to fully utilize “beam time,” and improving research outcomes. Developed by the Jackson, Wyoming-based Square One, the Tri-Sphere Robotic Positioning System offers unparalleled capabilities.

Square One’s patented Tri-Sphere robot is a parallel robot whose design meets the rigorous demands of high-energy physics research. Like revolute jointed industrial robots, the new robot offers six degrees of freedom in movement. Unlike traditional robots, the new robot delivers huge payload capacity, ultra-high precision, and a compact design that fits seamlessly into tight spaces. The new robot conforms to the EPICS standard (Experimental Physics Integrated Control System) which is widely adopted in the physics community. EPICS provides researchers and technicians with a standardized control system architecture and software toolkit to interface with and control high-end equipment. EPICS’ many toolkits improve process tracking performance and optimizes analysis of the metadata gathered during experiments.
SLAC’s deployment of Tri-Sphere robots is part of larger upgrades to their Linac Coherent Light Source (LCLS), the world’s most powerful X-ray free-electron laser. A recent upgrade (LCLS-II) increased the capabilities of the original system from 120 pulses per second to 1 million pulses per second, and a future upgrade (LCLS-II-HE) will increase the X-ray energy. This opens a new realm of advanced research projects previously considered impossible by scientists, including a new generation of solar energy technologies, superconductors, advanced drug discovery, and other areas.
Breaking through physics research limits
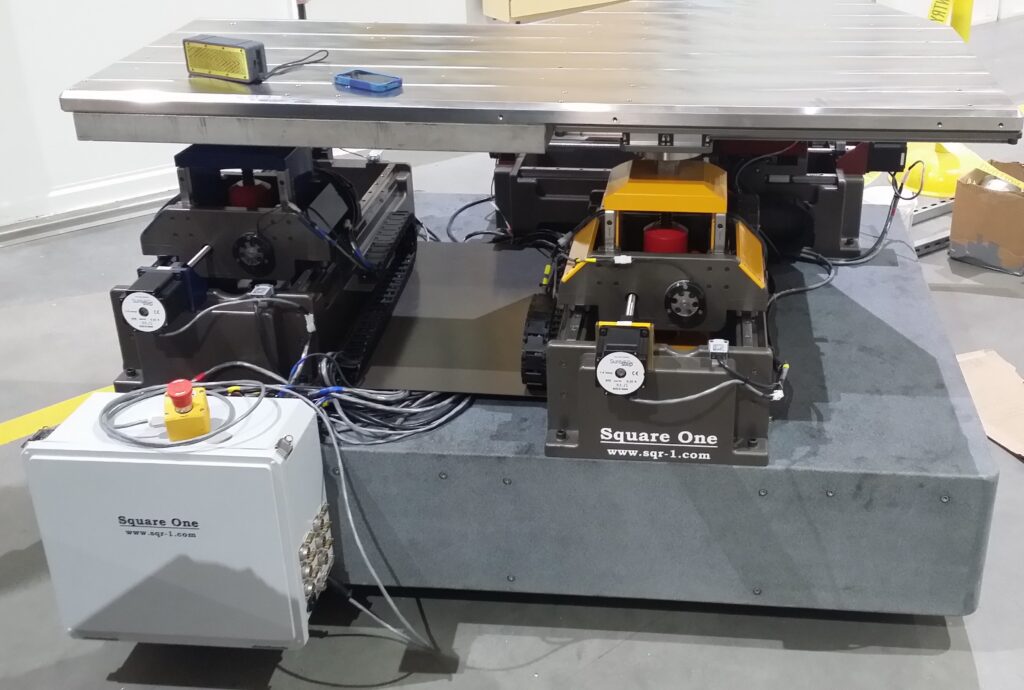
The unique design of the Tri-Sphere robot offers several advantages to accommodate the rapid succession (removal and replacement) of complex research setups and operate in the demanding environment typical of facilities like LCLS. The new robot’s compact geometry means it can fit into the tight confines of a mainstay in research facilities, the hutch, or the equipment used in research facilities where X-ray beams pass through test samples. A high-precision positioning system ensures that the robot can precisely move research equipment into beams as narrow as 100 nanometers.
The new robot supports rapid movement and repositioning of heavy objects with the accuracy required to perform cutting-edge experiments.
“The Tri-Sphere robot is designed with heavy payloads in mind and has the ability to handle up to 12,000 pounds – which is essential when positioning heavy objects in national labs like SLAC,” said Bob Viola, director of engineering at Square One Systems Design. “This performance far exceeds that of conventional robots that may be more suited to industrial use.”
Maximizing beam time is essential to accommodate as many experiments as possible.
“National labs like SLAC are literally priceless national resources, and every second of beam time counts,” Viola said. “The ability to perform quick changeovers without compromising precision or reliability is a game-changer.”
Jace Walsh, chief controls engineer at Square One, said, “The Tri-Sphere’s asymmetric work envelope and software-tunable rotation point provide unmatched versatility and precision, allowing it to adapt to a wide range of experiments. This flexibility is crucial for experiments, where the ability to quickly and accurately reposition experimental setups can significantly impact research outcomes.”
The upgrade integrates automation and control technology from Beckhoff across multiple experimental hutches, allowing SLAC to conduct high-precision experiments with minimal downtime. The staff can set up a new center for the beam in the Tri-Sphere’s user-friendly front-end software, dial in new configuration settings, and enter new height parameters and rotation settings.
The SLAC Tri-Sphere systems are mounted on air casters. This enables the robots to be quickly moved in and out of different hutches. The Tri-Sphere can handle delicate samples with precision, another key advantage.
“The robot features a vacuum transfer system to ensure that the system can handle a wide variety of container types without damage, including delicate products with soft-touch finishes,” said Viola. “This is crucial for experiments using highly sensitive sample materials.”
Automating what’s next in research and discovery
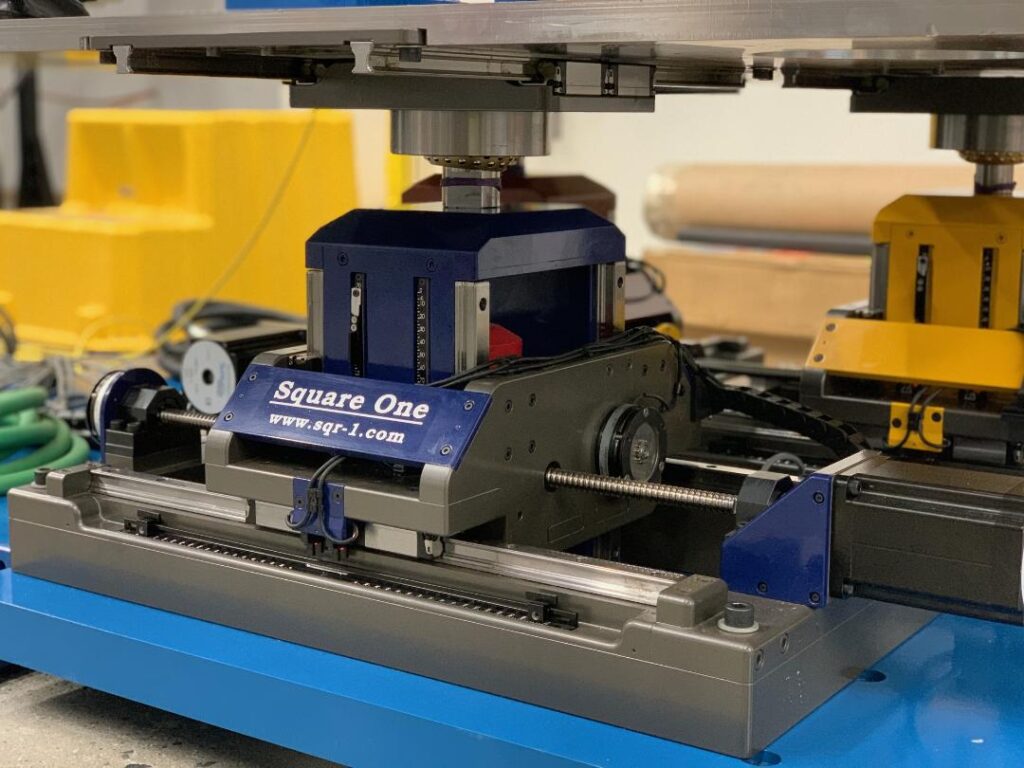
Instrumental to the success of the robotic positioning system has been the integration of PC- and EtherCAT-based control technology from the automation supplier. The Tri-Sphere currently relies on embedded PCs as the primary controller, leveraging real-time EtherCAT communication and high processing speeds to seamlessly handle all automation and control tasks. The embedded PC software for motion control.
“As a clean, all-in-one package,” Walsh said, “advanced automation technologies have been instrumental in optimizing the Tri-Sphere system’s performance,” says Walsh. “The real-time EtherCAT communication and fast processing speeds” of the embedded PC made this possible, he said. “Unlike traditional PLC technologies, PC-based automation allows us to handle all automation and control functionality on one device, with seamless integration” across the automation platform, the robot controller, and the machine vision system.
EtherCAT’s automatic addressing of its highly modular devices, numerous wiring topology options, and high device count – up to 65,535 devices in one network – ensure a robust and scalable network infrastructure. In addition, the compact size of the DIN-rail mounted EtherCAT communication terminals easily fit in compact enclosures distributed throughout the robot.
Not just relegated only to data acquisition, the terminals can also incorporate compact drive technology. Integrated stepper motor terminals handle some Tri-Sphere’s motion requirements. The system also leverages dual interface terminals for the required encoders, enabling direct connection of absolute encoders with BiSS C or SSI interface.
Safety I/O terminals and Safety over EtherCAT (FSoE) technology provide robust machine safety functionality that integrates seamlessly with SLAC’s personnel protection system and equipment protection connections from the lab for sending safety status whenever personnel are in a hutch and initiating e-stops if they’re ever needed.
“TwinSAFE supports these unique safety requirements, ensuring safe access to the hutches at all times and reliable control of these powerful positioners,” said Viola.
The Tri-Sphere system is compatible with the seismic anchoring requirements typical of installations in California. This ensures that the systems can withstand seismic activity and maintain their precise positioning. Through a kinematic base designed by Square One, the Tri-Sphere meets the demanding requirements to withstand extreme vibrations.
A high-energy future for the world’s leading research projects
“When SLAC can prepare an experimental work setup on a Tri-Sphere outside of the working hutch without shutting down the beamline, it speeds things up,” Viola says. “The system reduced the time required for SLAC experiment changeovers from two days to just 12 hours.”
Square One is expanding use of the new system.
“We are in the process of upgrading several older Mark IV systems around the country to Beckhoff controllers and exploring new applications for Tri-Sphere technology,” said Viola. “Flexibility and scalability” of the automation and control solutions are key to fueling our ongoing innovation, he said.
Looking ahead, the potential applications for the Tri-Sphere Robotic Positioning System are vast. Advanced diagnostics and modularity of the automation have been “crucial in achieving new levels of safety and reliability,” Walsh said. The automation company’s responsiveness and commitment to application engineering and technical support with field engineers have helped.
The Tri-Sphere, as demonstrated by its successful deployment at SLAC, is helping overcome key challenges in many areas of scientific research. With proven flexibility and performance to adapt to a wide range of difficult testing spaces, the system has since been deployed at other world-renowned laboratories to help reach the next big discovery.
Shane Novacek is marketing communications manager, Beckhoff Automation LLC. Edited by Mark T. Hoske, editor-in-chief, Control Engineering, WTWH Media, [email protected].
Keywords
Motion control, machine safety, robots
Consider this
Robotic system designs can provide precise repeatable motion control.
Inside look
The Square One engineering team includes Sam Johnson (mechanical engineer), Wilton Springer (mechanical engineer), Connor McCullough (electrical engineer), Erik LaCourt (controls engineer) Bob Viola (director of engineering), Jace Walsh (controls engineering manager), Ryan Freeman (mechanical engineer), Dena Horstkotte (mechanical engineer). Beckhoff Automation field engineers, including Ryan Kirkland, provided project support.
You also might like
Make exponential gains now: Automation, I/O, mechatronics
Control Engineering provides more on robotic motion https://www.controleng.com/mechatronics/robotics/